Find Your Model's Real-World Failure Modes Before It Flies.
Deploy your UAV perception models, obstacle detection networks, SLAM pipelines, and navigation policies against real-world inputs from a global contributor network across 8 environment types. Find where your simulation-trained model fails — before it fails in the field.
The UAV Eval Pipeline
From model integration to production-ready training data — grounded in real-world inputs, not controlled test benches.

Integrate Your Perception Model
Connect your UAV perception, obstacle detection, or navigation model to Pioggia via API — in hours, not weeks.

Deploy Against Real-World Inputs
Contributors capture edge-case environments simulation never modeled — dense vegetation, low-visibility conditions, novel terrain — and submit model inputs through the platform.

Segment for Training
Model outputs and scenario responses are automatically segmented and structured for reward model training — ready for your RLHF pipeline.

Human Evaluation of Model Outputs
Contributors rate, compare, and annotate outputs across obstacle detection accuracy, navigation decision quality, environmental generalization, and edge-case handling. Signals flow into your pipeline automatically.

Eval Report Delivered
An audited eval report with actionable insights, failure mode analysis, and a clean dataset ready for your next training run.
What real-world evaluation does for your UAV model
Simulation test benches show you what you designed for. Real-world human evaluation shows you what you missed.
Reduce false obstacle detections
Human evaluation of multi-class detection outputs across real-world environments surfaces false positive and false negative rates controlled test sets miss — grounded in real sensor noise, not simulated distributions.
Close environment generalization gaps
AirSim- and Isaac Sim-trained models fail on real sensor noise. Deploy against real-world inputs from 8 environment types worldwide — find the gaps before your UAV does.
Build preference data for navigation decisions
Side-by-side comparisons generate navigation decision preference data and detection confidence calibration pairs — what your reward model needs to learn good autonomous behavior at real-world scale.
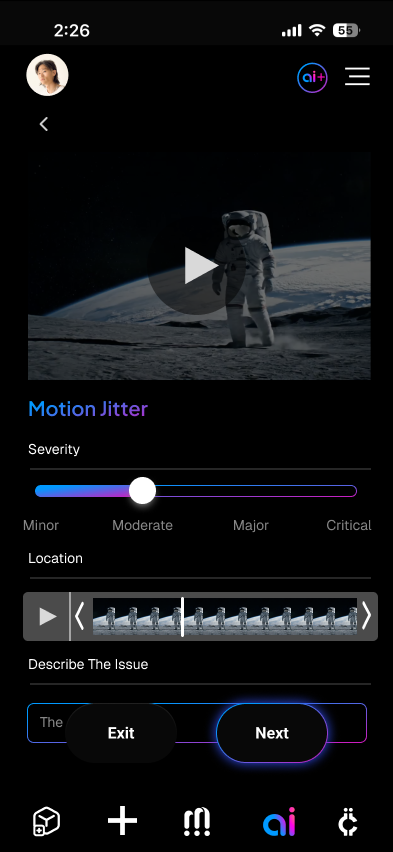
Granular Quality Signals for Perception Models
Beyond pass/fail — contributors evaluate detection IoU thresholds, false positive rates by environment type, navigation waypoint accuracy, and SLAM drift. Each dimension feeds your RLHF reward model as a structured, labeled signal.
The result: a reward model that knows exactly what good UAV perception looks like across real-world environments — not a proxy metric from a test bench, but real human judgment at network scale.
What you get when real people evaluate your UAV model
Real human evaluation across real environments — not synthetic proxies or lab runs. The signal that separates UAV models that deploy from ones that fail in the field.
Find your model's failure modes before it flies.
Integrate your UAV perception model with the Pioggia eval pipeline. We'll scope a pilot and show you exactly where real-world conditions break it.
Book a Scoping Call